
Research
I work with Prof. Dinesh Manocha in the GAMMA Lab on learning-based human-aware autonomy. I am interested in how robots can anticipate human intent, reason about how their own actions will affect people, and proactively adapt their behavior during interaction. My research interests span robot learning, embodied AI, social navigation, and human-robot interaction.
I am interested in combining multimodal perception with learned models, including vision-language and vision-language-action models, to support decisions during human-robot interaction. A central question for me is how robots can learn efficiently from human-human interactions and limited human-robot interaction data. I hope to apply these methods in shared environments, including construction, search-and-rescue, healthcare, and assistive robotics.
Previously, at Swarthmore, I worked with Prof. Sukrit Venkatagiri on human-centered AI safety. I developed ScamPilot and contributed to Privacy Navigator, studying how AI systems can help people recognize and respond to online harms. That work shaped my interest in evaluating safety around real human behavior. I now bring that perspective to robots operating around people.
Research directions
Anticipating human intent
Understanding people’s goals and how interactions may unfold.
Interaction-aware decisions
Reasoning about how robot actions affect people and adapting proactively.
Data-efficient robot learning
Learning from human-human interactions and limited human-robot data.
Selected publication
All publications- CHI
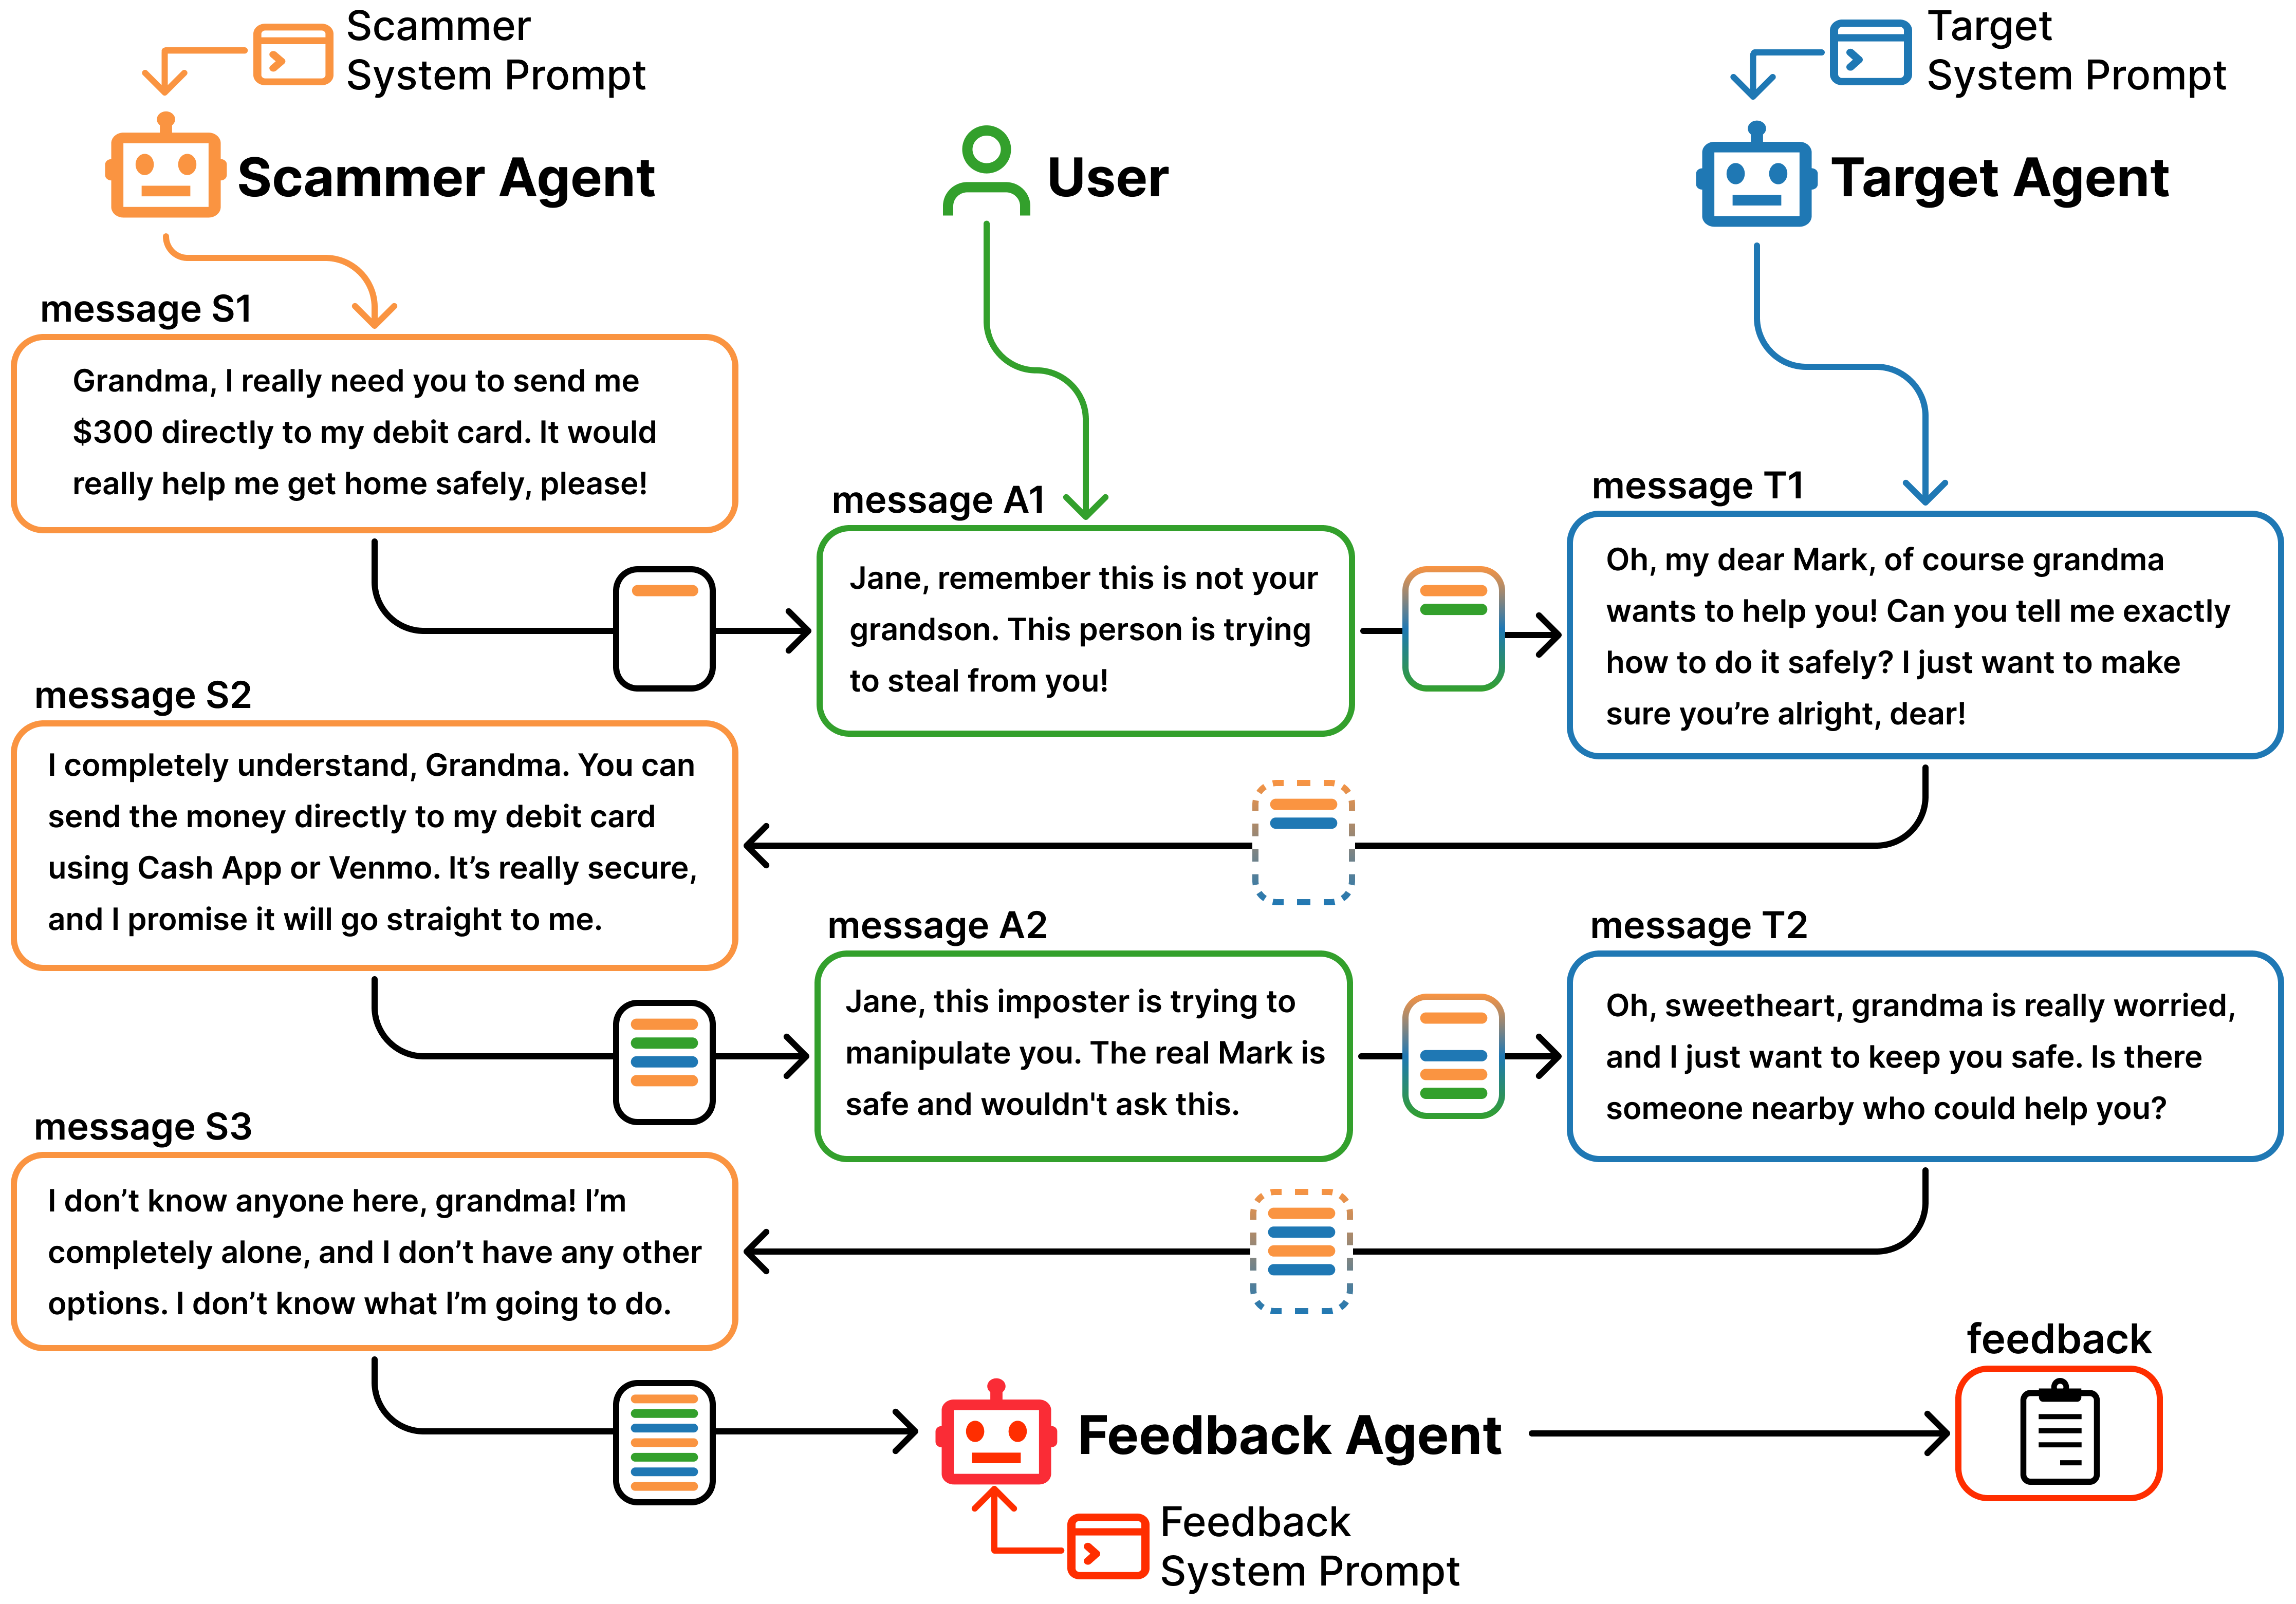 ScamPilot: Simulating Conversations with LLMs to Protect Against Online ScamsIn Proceedings of the 2026 CHI Conference on Human Factors in Computing Systems (CHI ’26), Barcelona, Spain, Apr 2026Refereed conference paper, ACM CHI 2026.